Ekejime Robot

An automated fish-processing system developed to perform the ikejime process through integrated pneumatic and electrical subsystems while operating in a wet industrial environment.

Ekejime robotic automation system
Back to Projects

Project Summary

The Ikejime Robot project focused on the development of an automated system designed to perform the ikejime process used in fish processing. My primary responsibilities included designing the complete pneumatic system, developing the plumbing layout, implementing system safety features, and creating the waterproof 120 VAC electrical harness. The project required careful integration of pneumatic and electrical components to ensure reliable operation in a demanding processing environment.
Images

Ekejime automation system
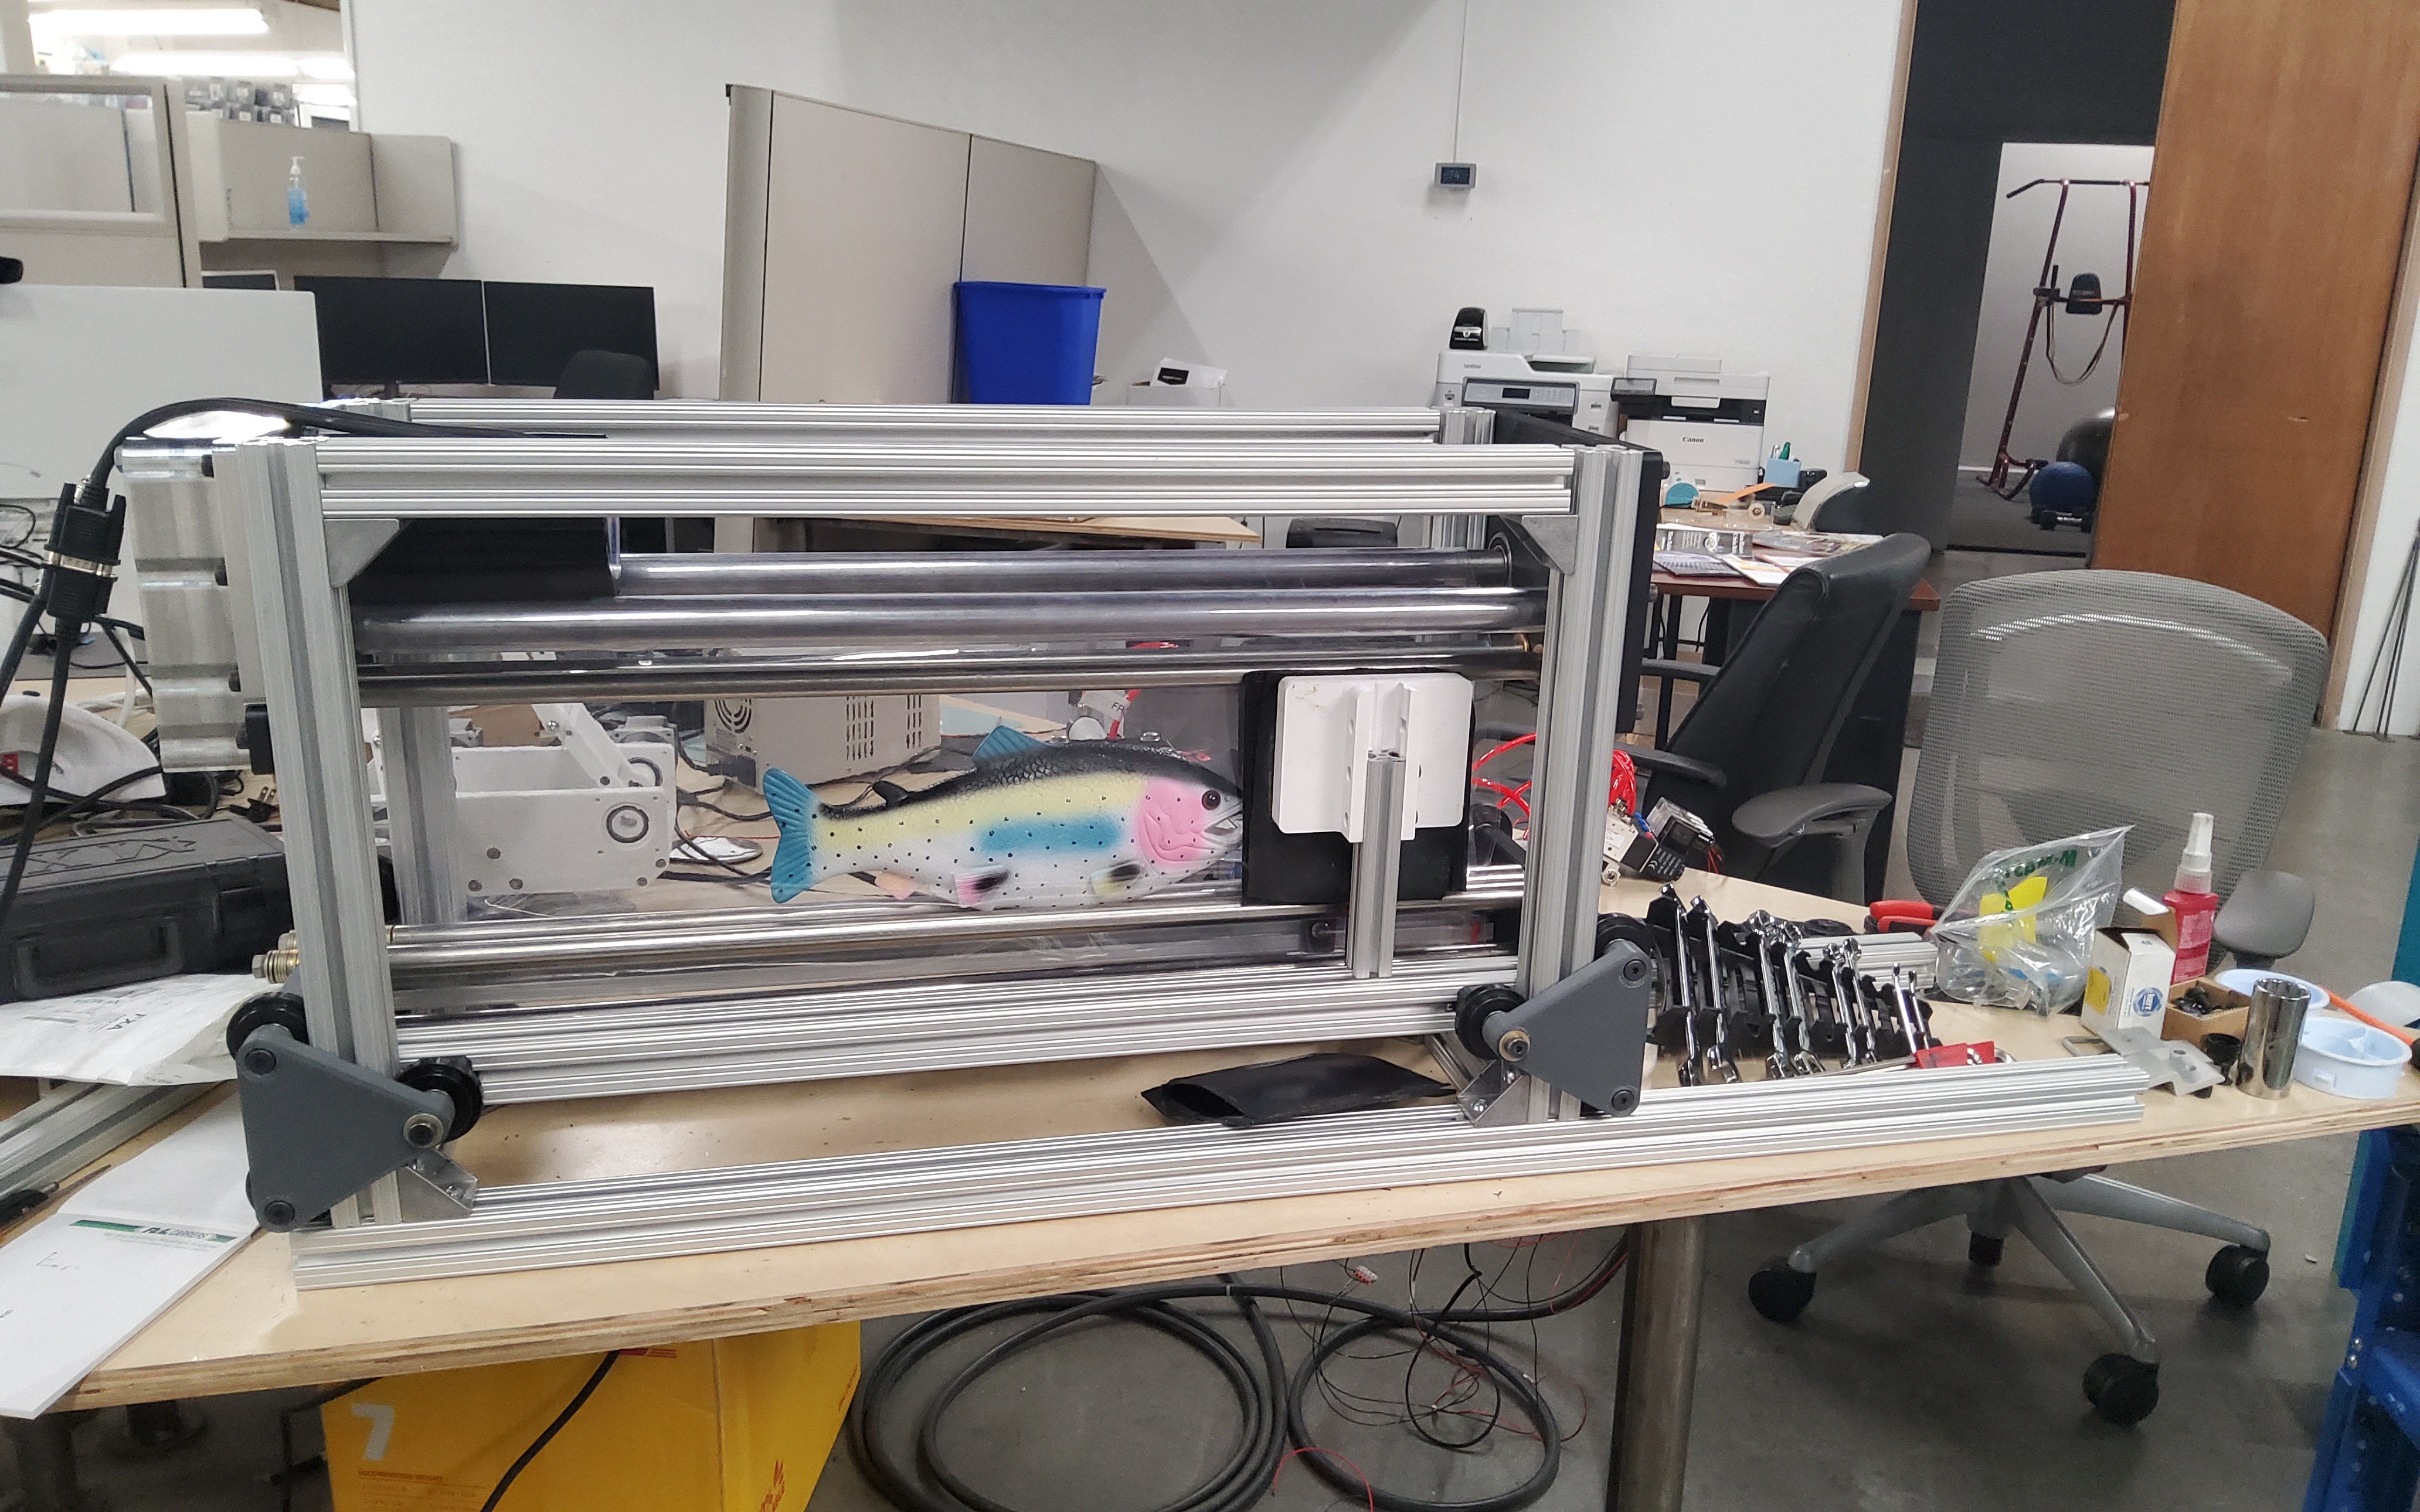
Automation system concept.
Ekejime pneumatic and plumbing system
Pneumatic and plumbing design.
Ekejime electrical and safety integration
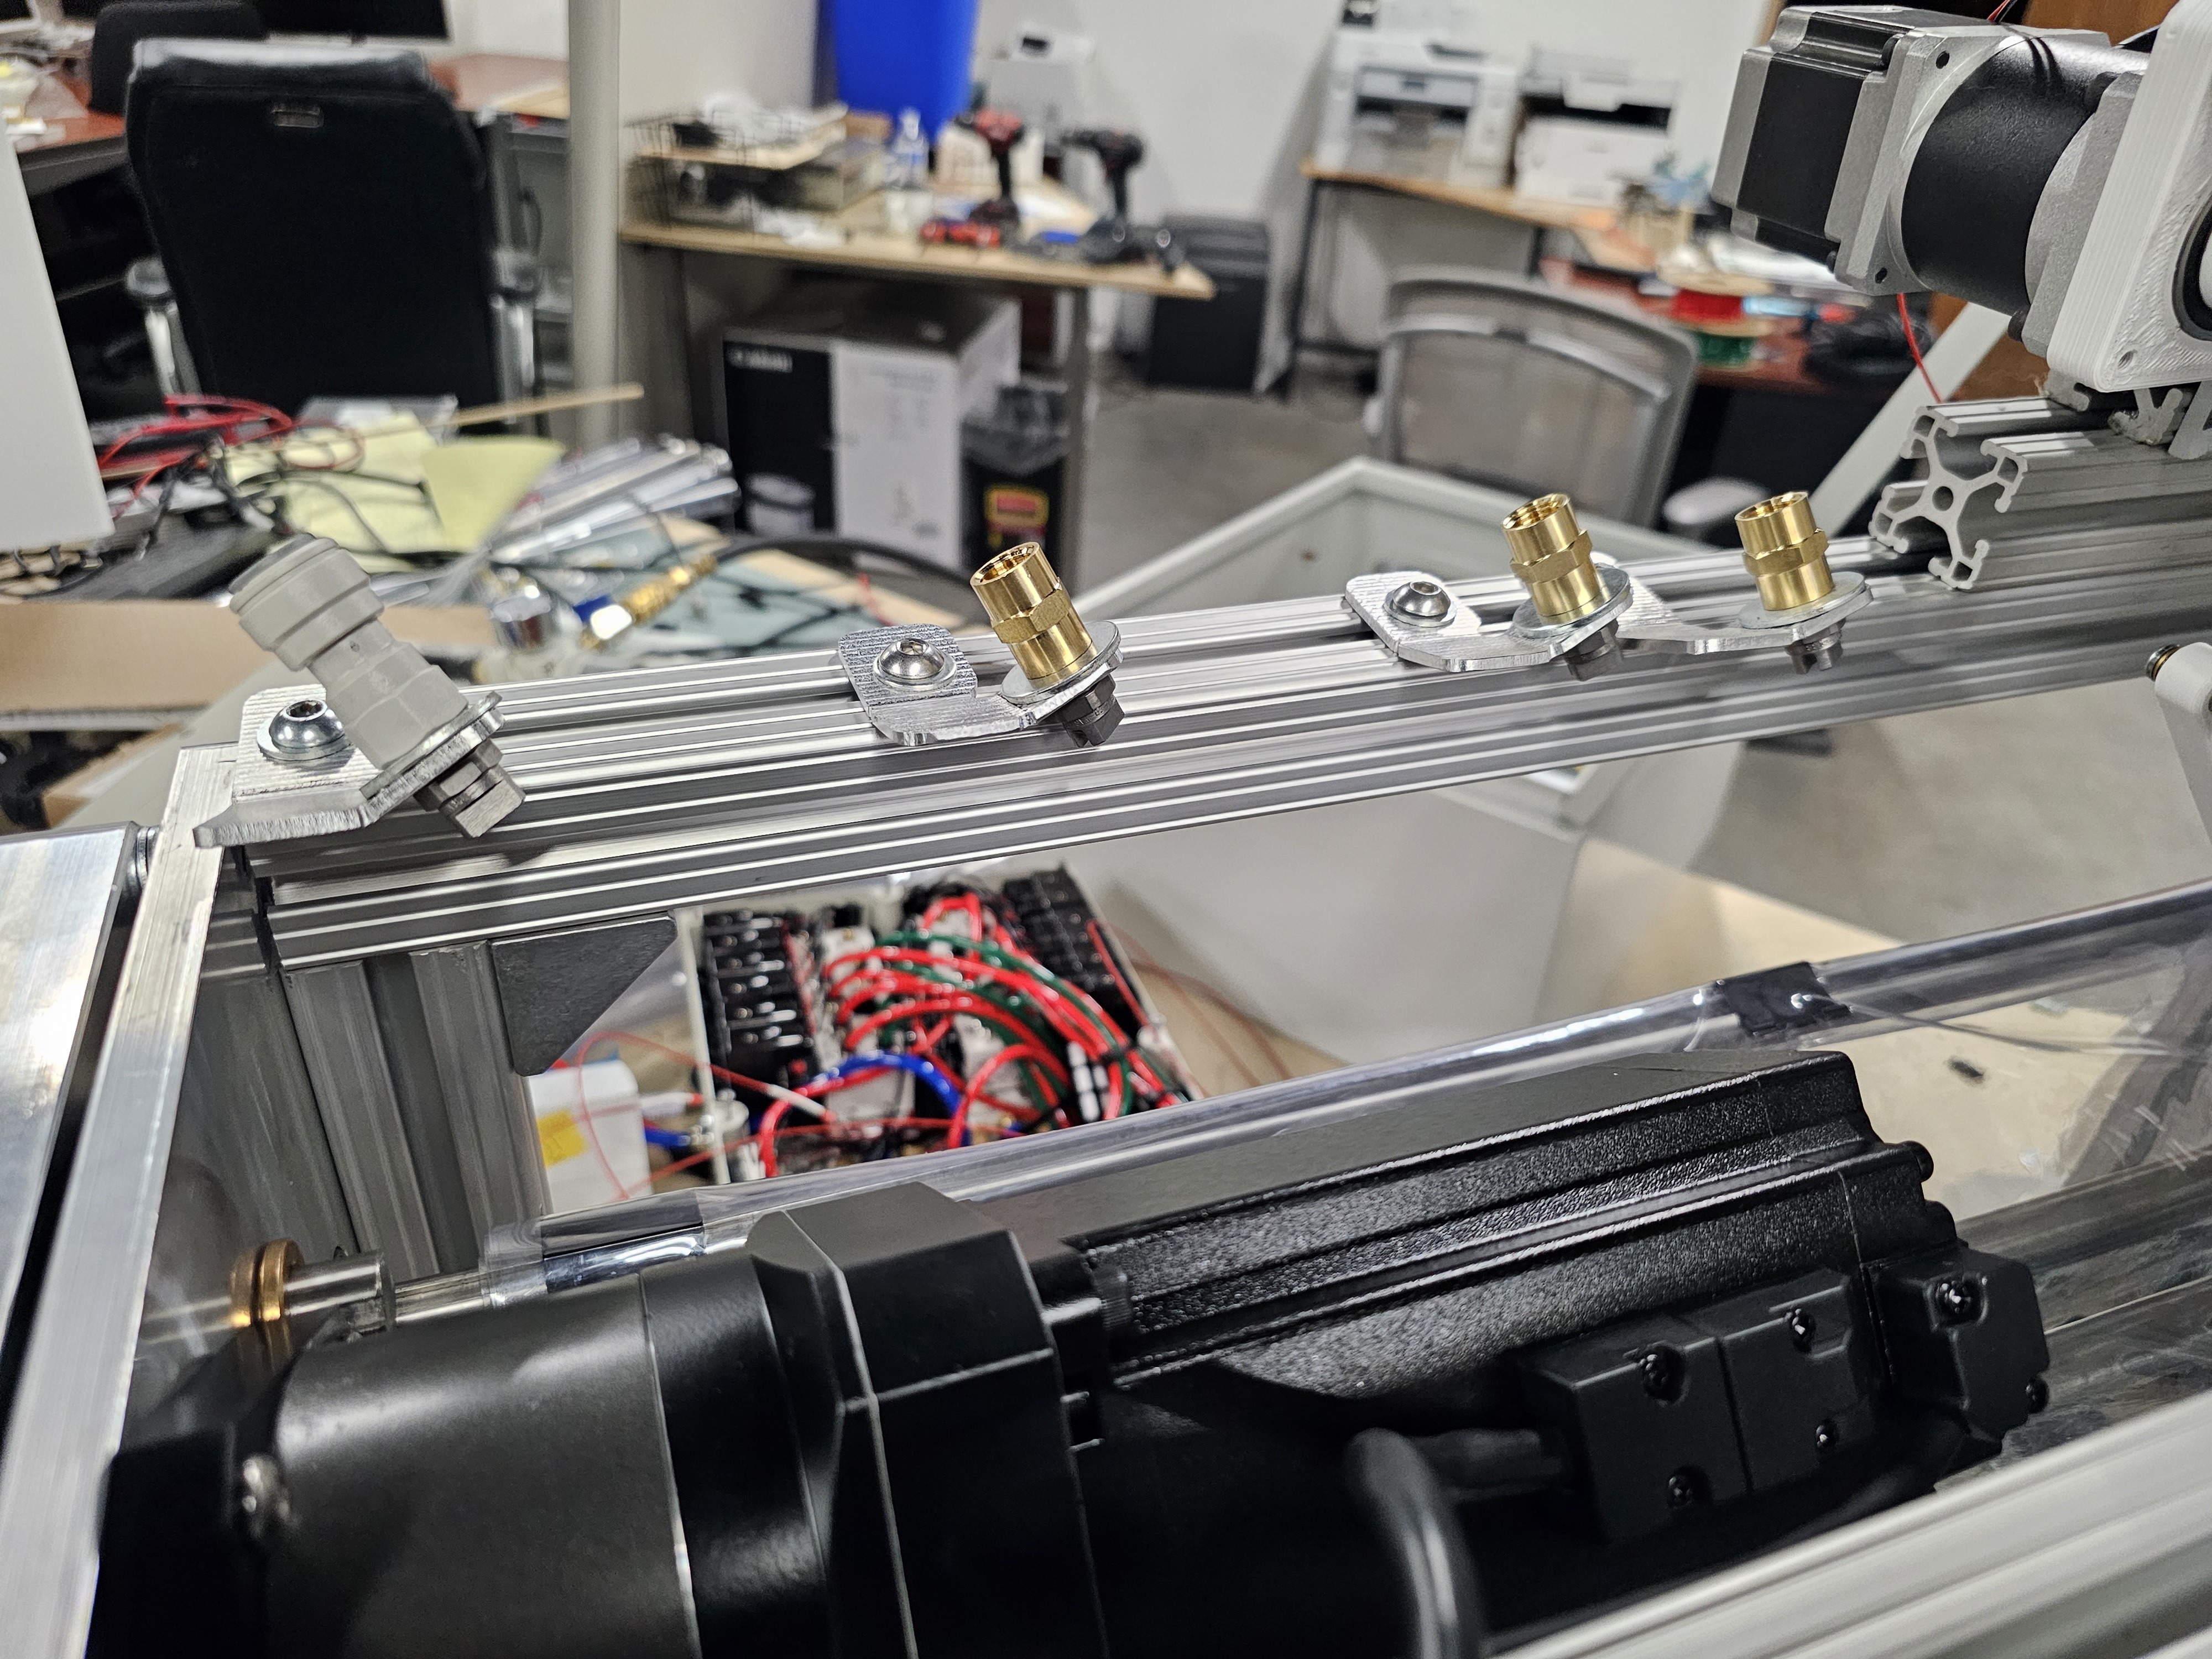
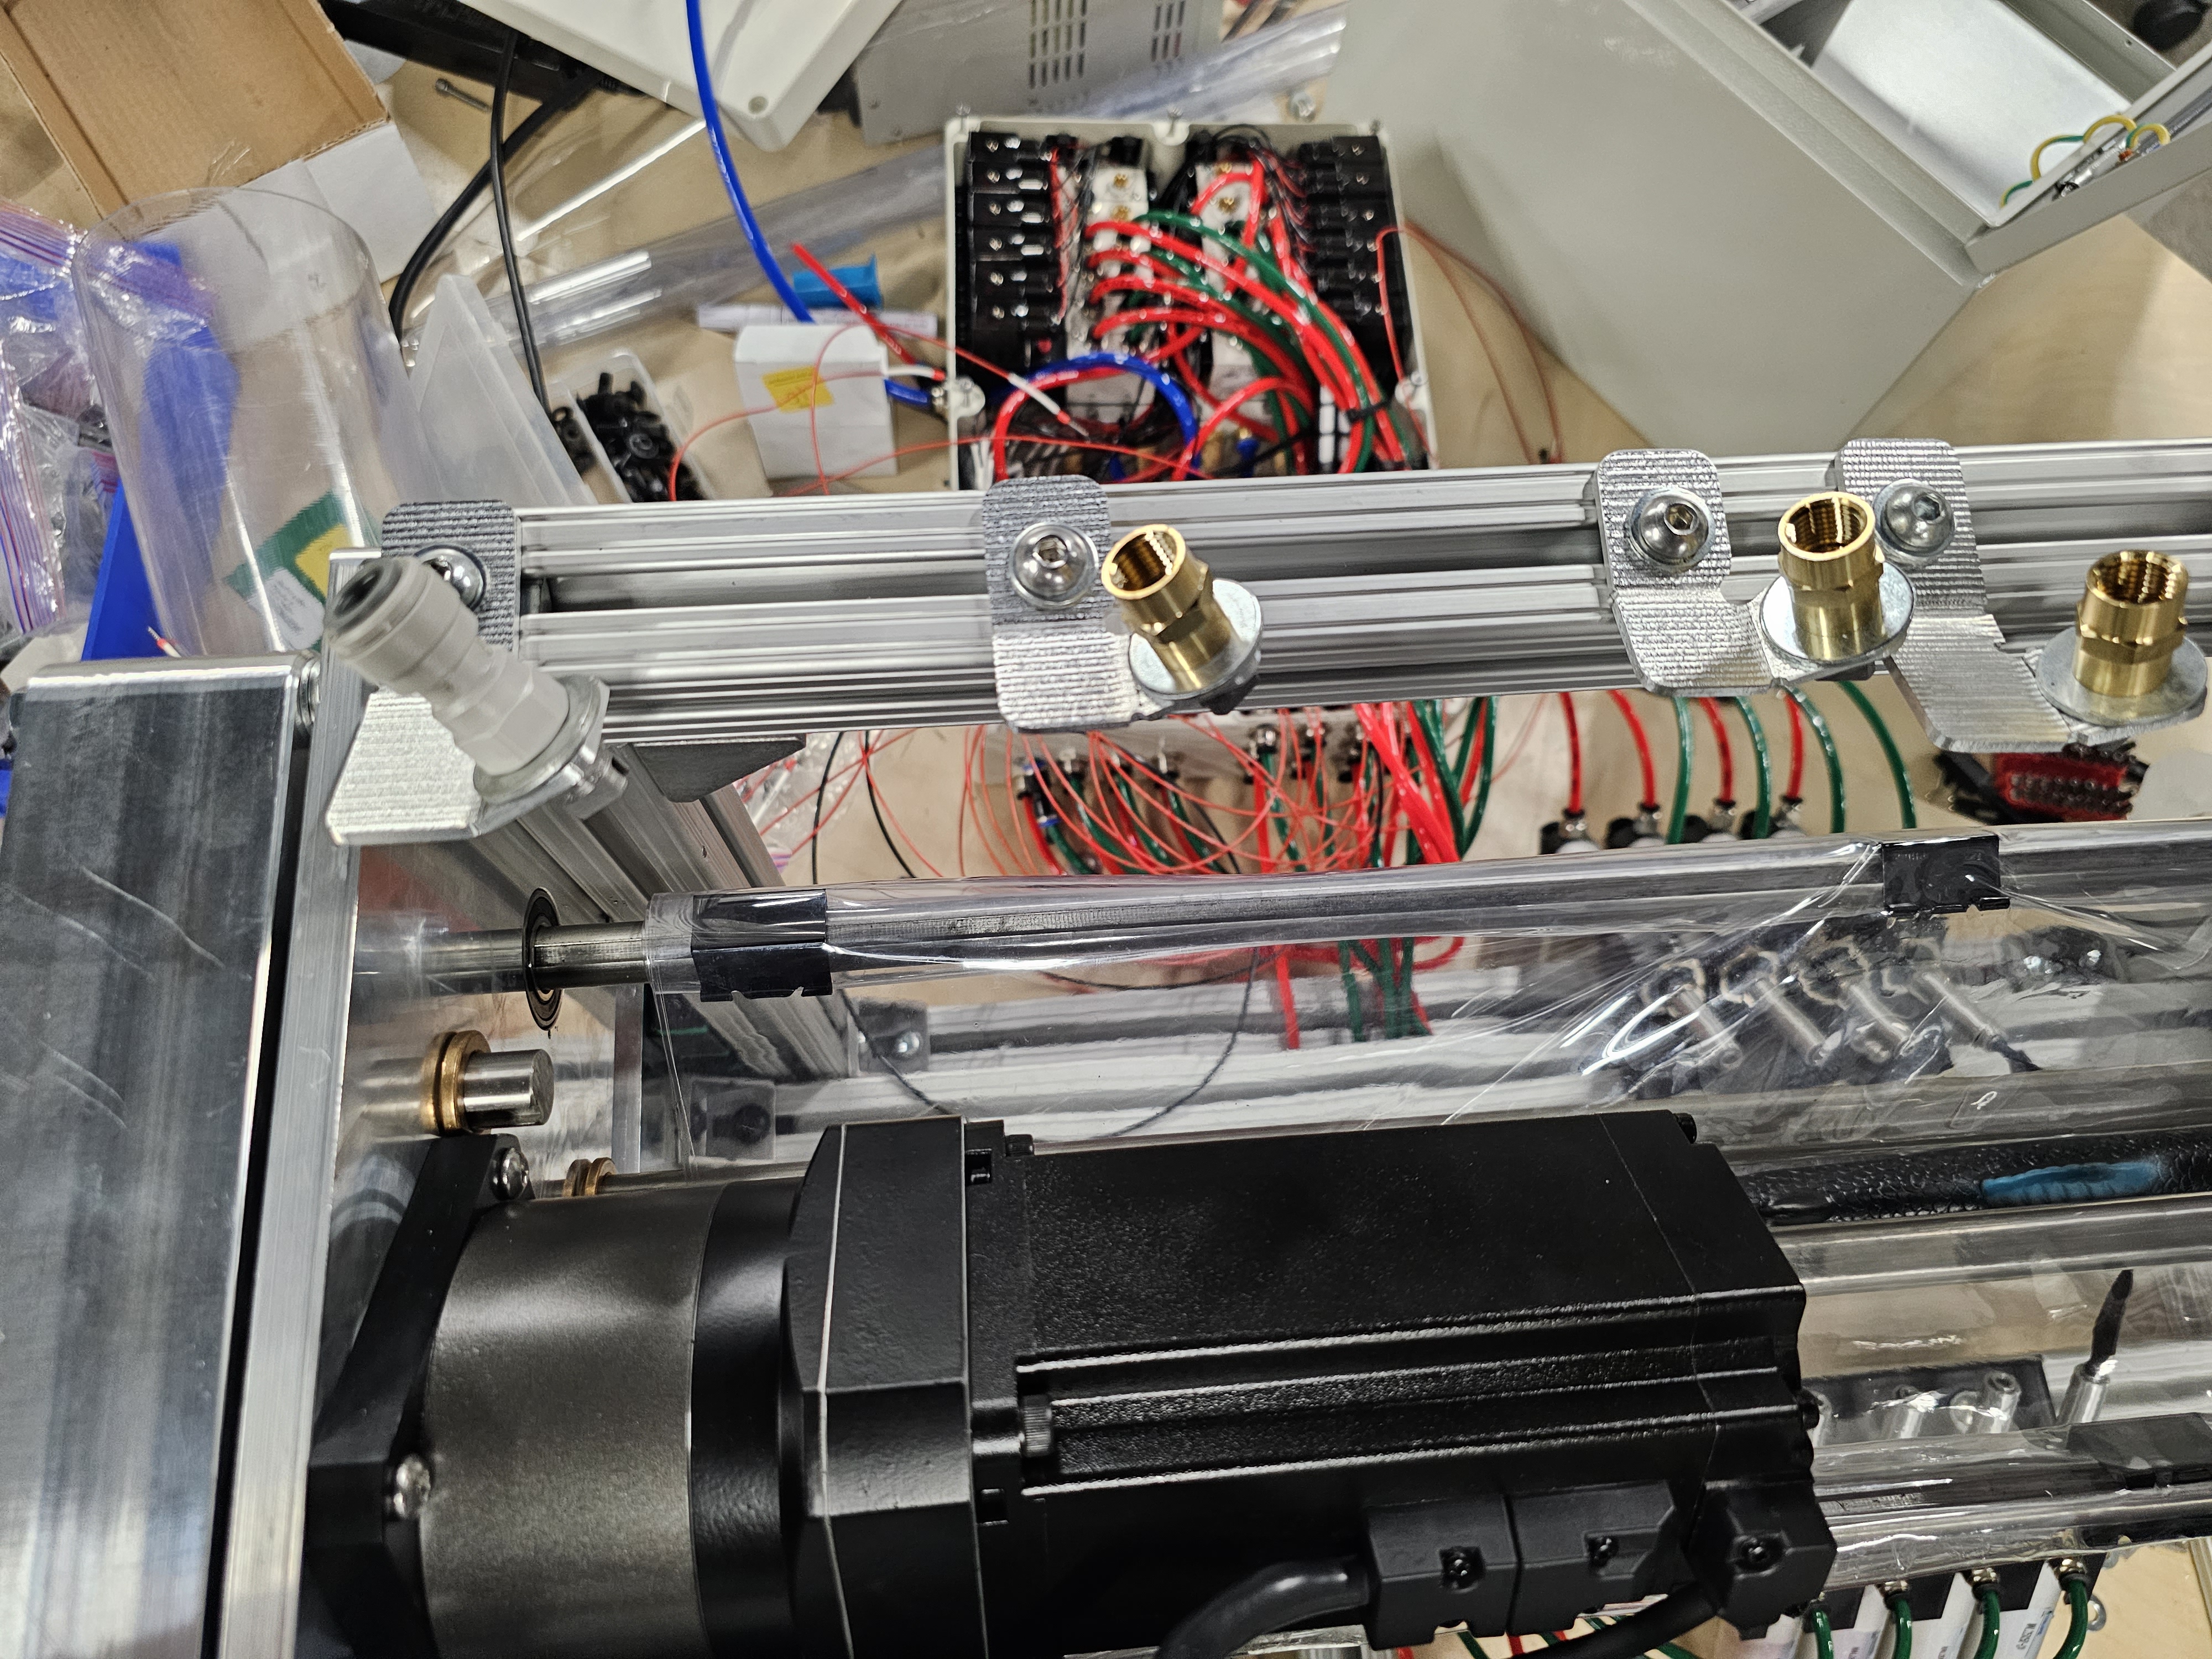
During development of the Ikejime machine, I tested the pneumatic system and plumbing to verify proper operation of the actuators and airflow throughout the system. In the background, the pneumatic control assembly uses color-coded tubing to distinguish the input and output air lines, making the system easier to troubleshoot, maintain, and assemble.
Ekejime robotic system project view
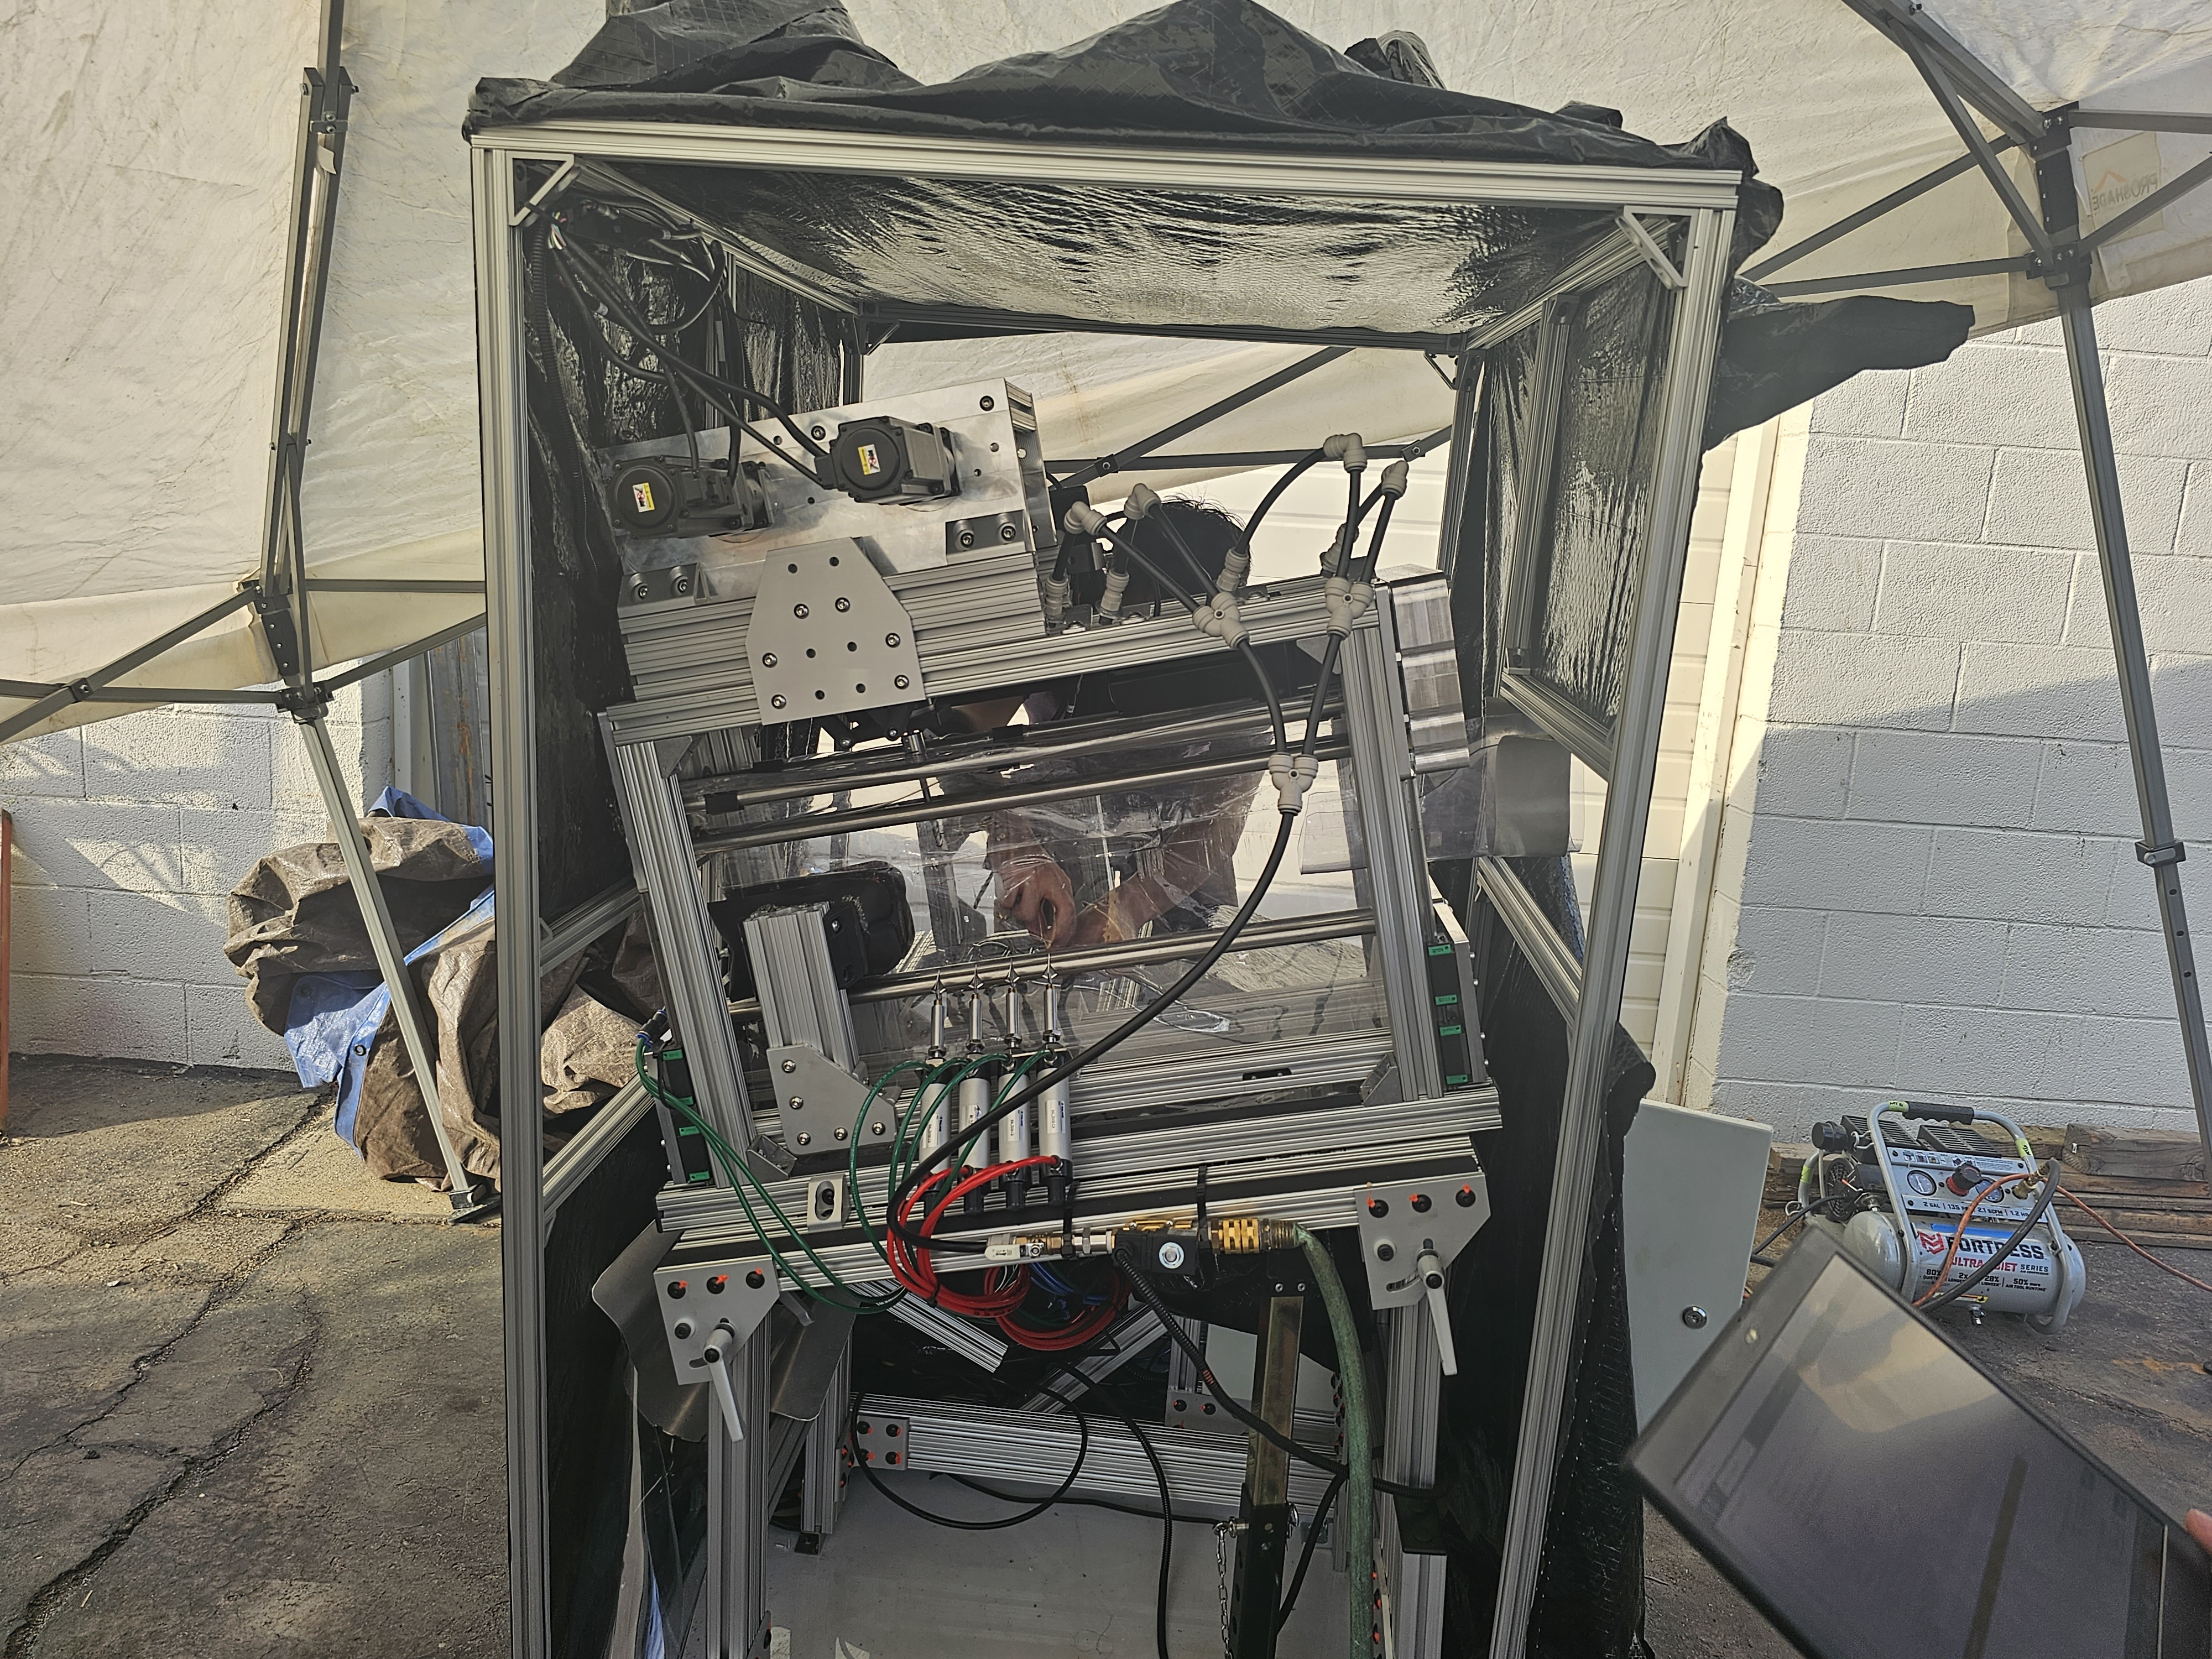
Preparing the Ikejime machine for one of its first tests using a dead fish required verifying the mechanical, pneumatic, and electrical systems together. This stage allowed us to evaluate how the complete machine operated under more realistic conditions and identify any adjustments needed before progressing to further testing.