Apple Harvester

Robotic harvesting system designed to pick, and collect apples while minimizing fruit damage and reducing labor requirements in orchard operations

Robotic apple harvesting system
Back to Projects

Project Summary

The Apple Harvester project focused on developing an autonomous robotic system capable of locating, harvesting, and collecting apples directly from orchard trees. The system combined a robotic arm, custom end effector, and machine vision system to identify fruit, position the manipulator, and remove apples from the tree while minimizing bruising and damage.

Once a fruit was detected, the vision system provided location data that allowed the robotic arm to move into position using inverse kinematics. The end effector was designed to gently grasp and twist the apple from its stem before transferring it through the collection system. The goal of the project was to improve harvesting efficiency while helping growers address labor shortages through agricultural automation.
Images

Apple harvesting system project image
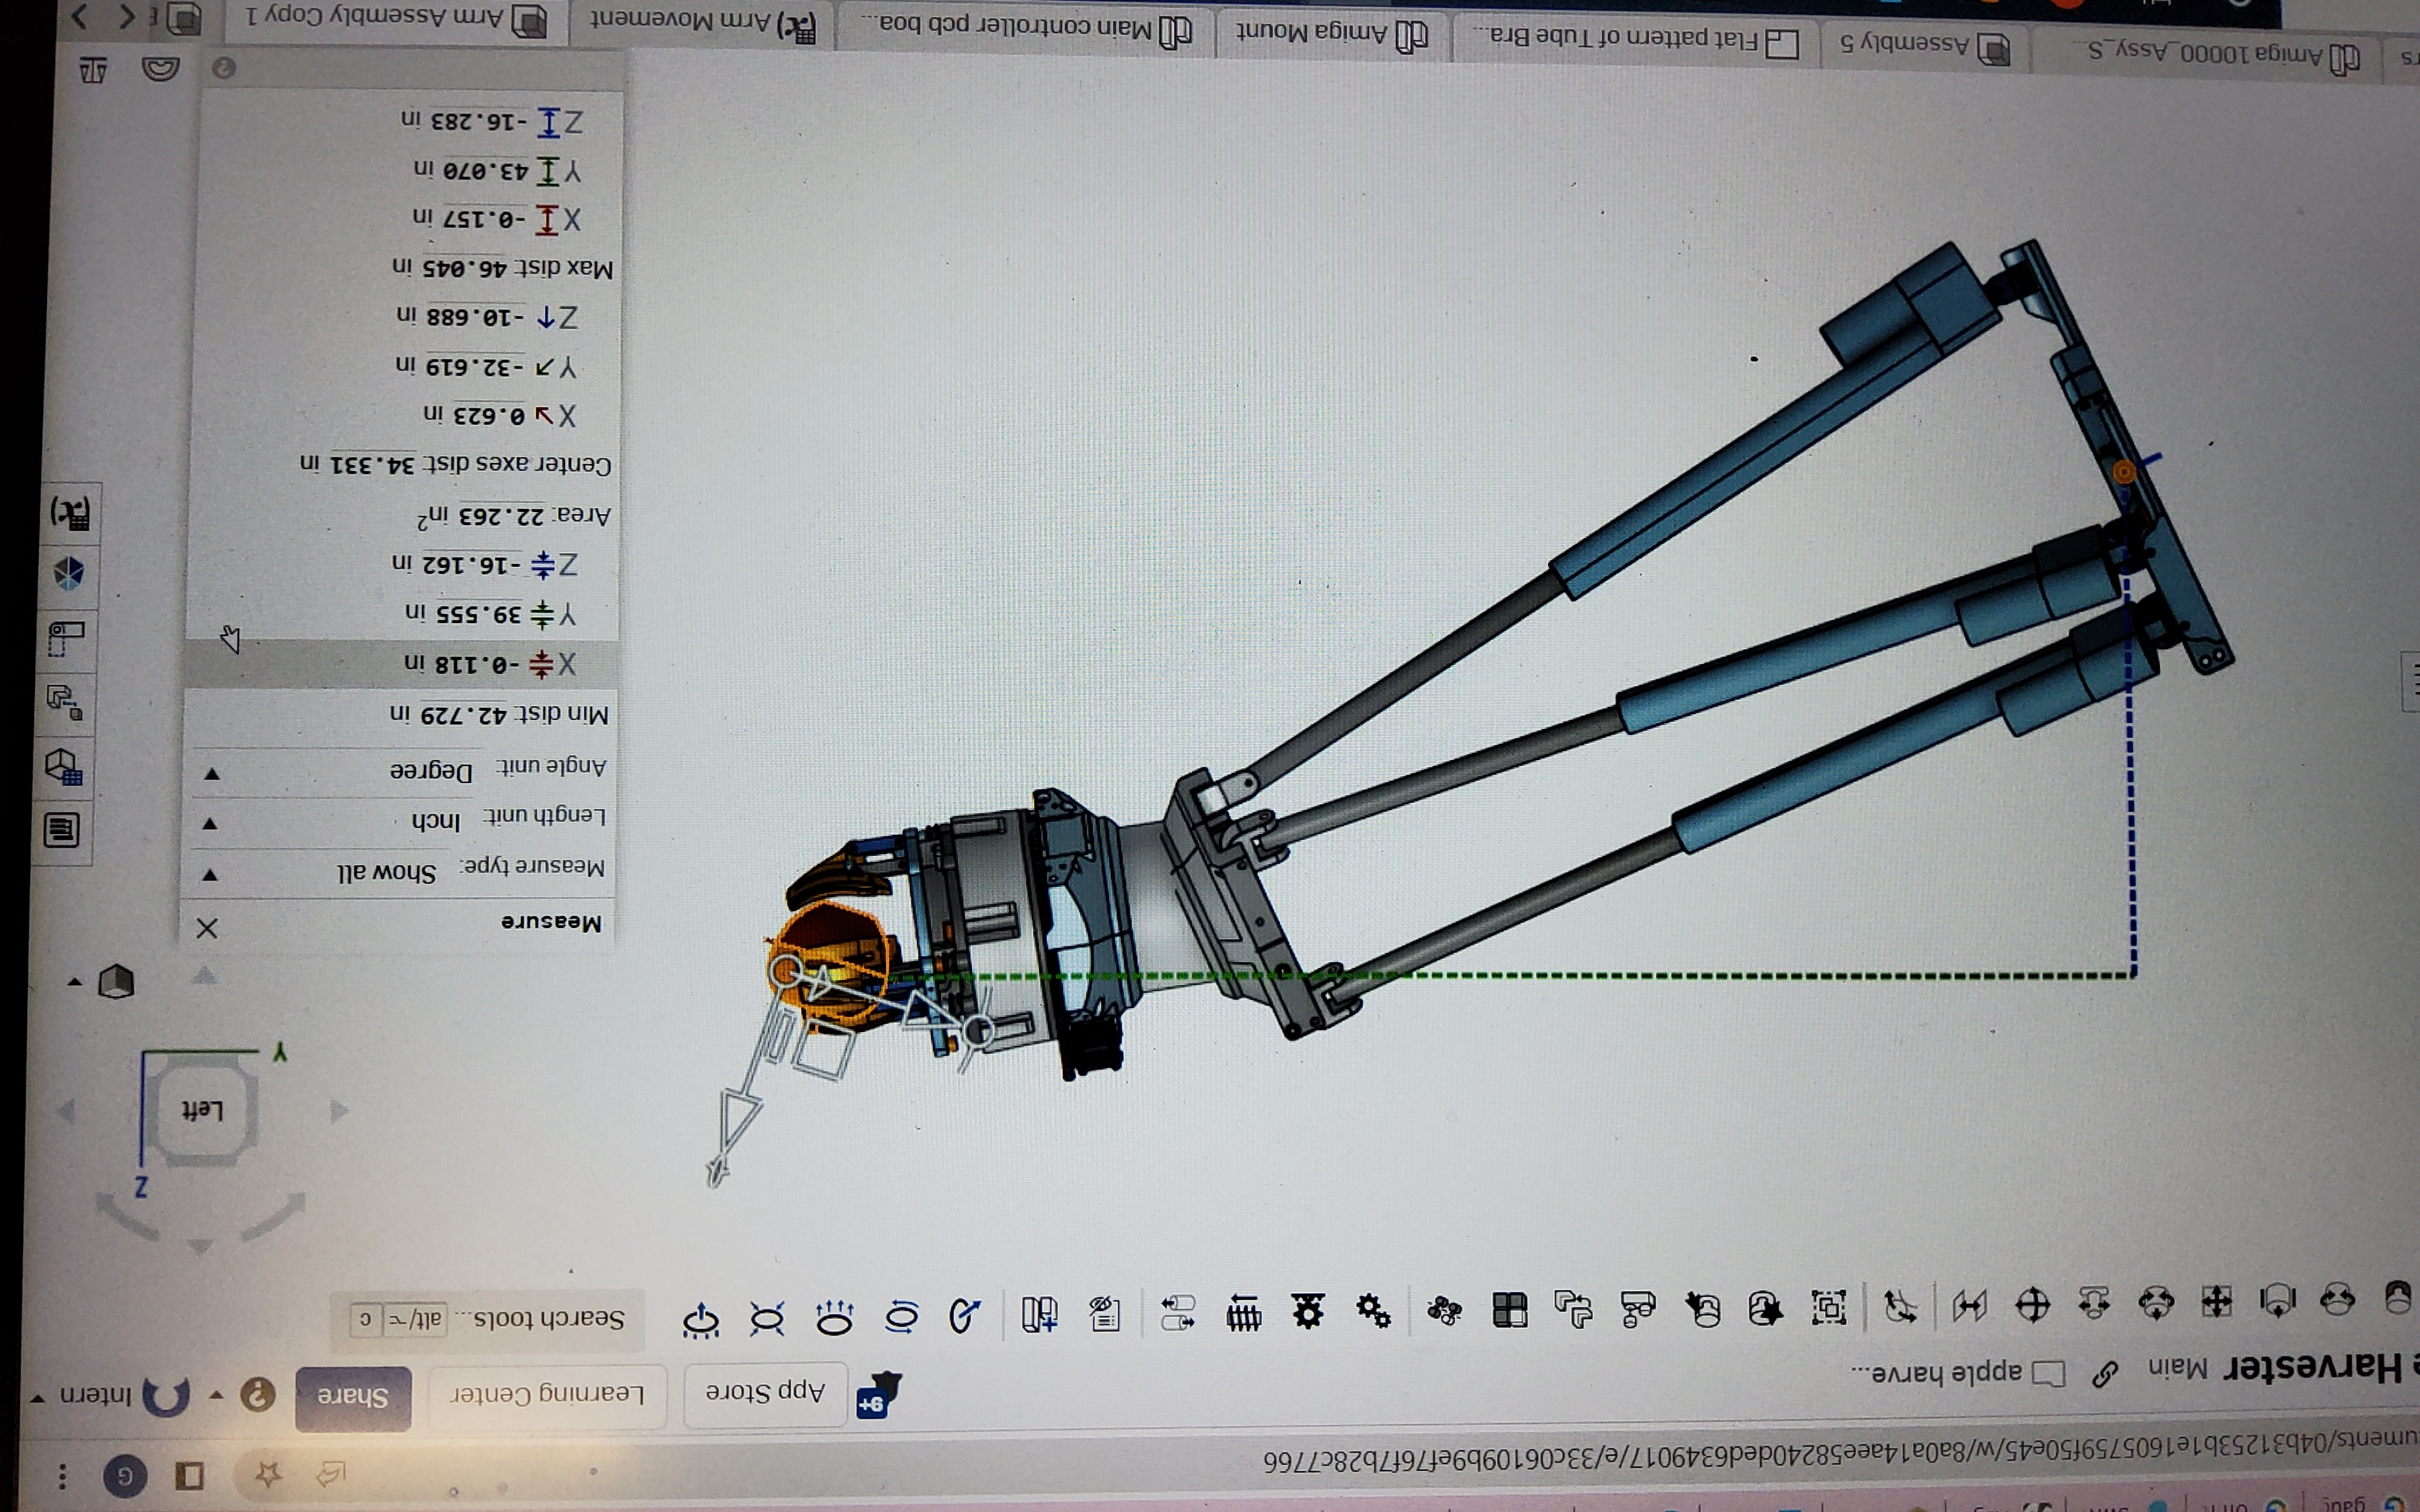
For the second iteration of the apple harvester, the robotic arm was redesigned and modeled in Onshape. This version explored a more developed mechanical architecture for positioning the end effector around the fruit while continuing to refine the overall harvesting concept.
Robotic apple harvesting prototype
Early development of the apple harvester focused on testing an iris-style end effector for capturing and collecting apples. This first prototype allowed us to evaluate the gripping concept and better understand the mechanical requirements needed to handle the fruit during harvesting.
Apple harvesting system design
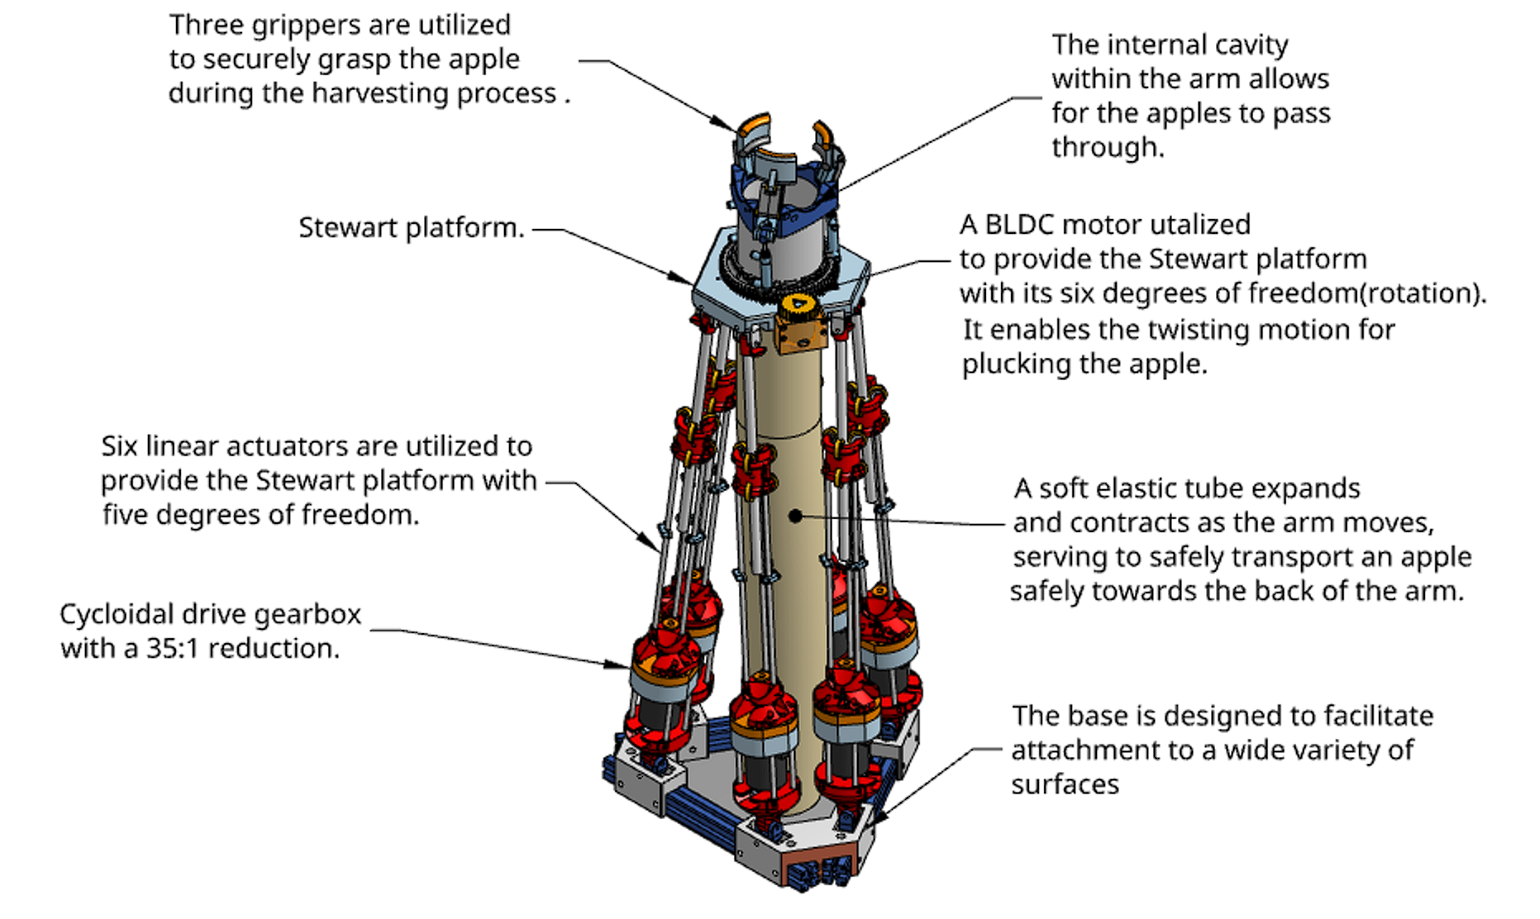
By the third iteration, the apple harvester had evolved into a Stewart-platform-based design that provided multiple degrees of freedom for positioning and orienting the harvesting mechanism. Pneumatic actuators were also incorporated into the end effector to operate the gripping system, creating a more integrated approach to reaching, gripping, and harvesting the apples.